
How the field winding is connected decides whether a DC motor holds steady speed or delivers huge starting torque.
DC motor types are classified by how the field winding is connected to the armature. That single choice sets speed regulation, starting torque and the applications each motor suits.
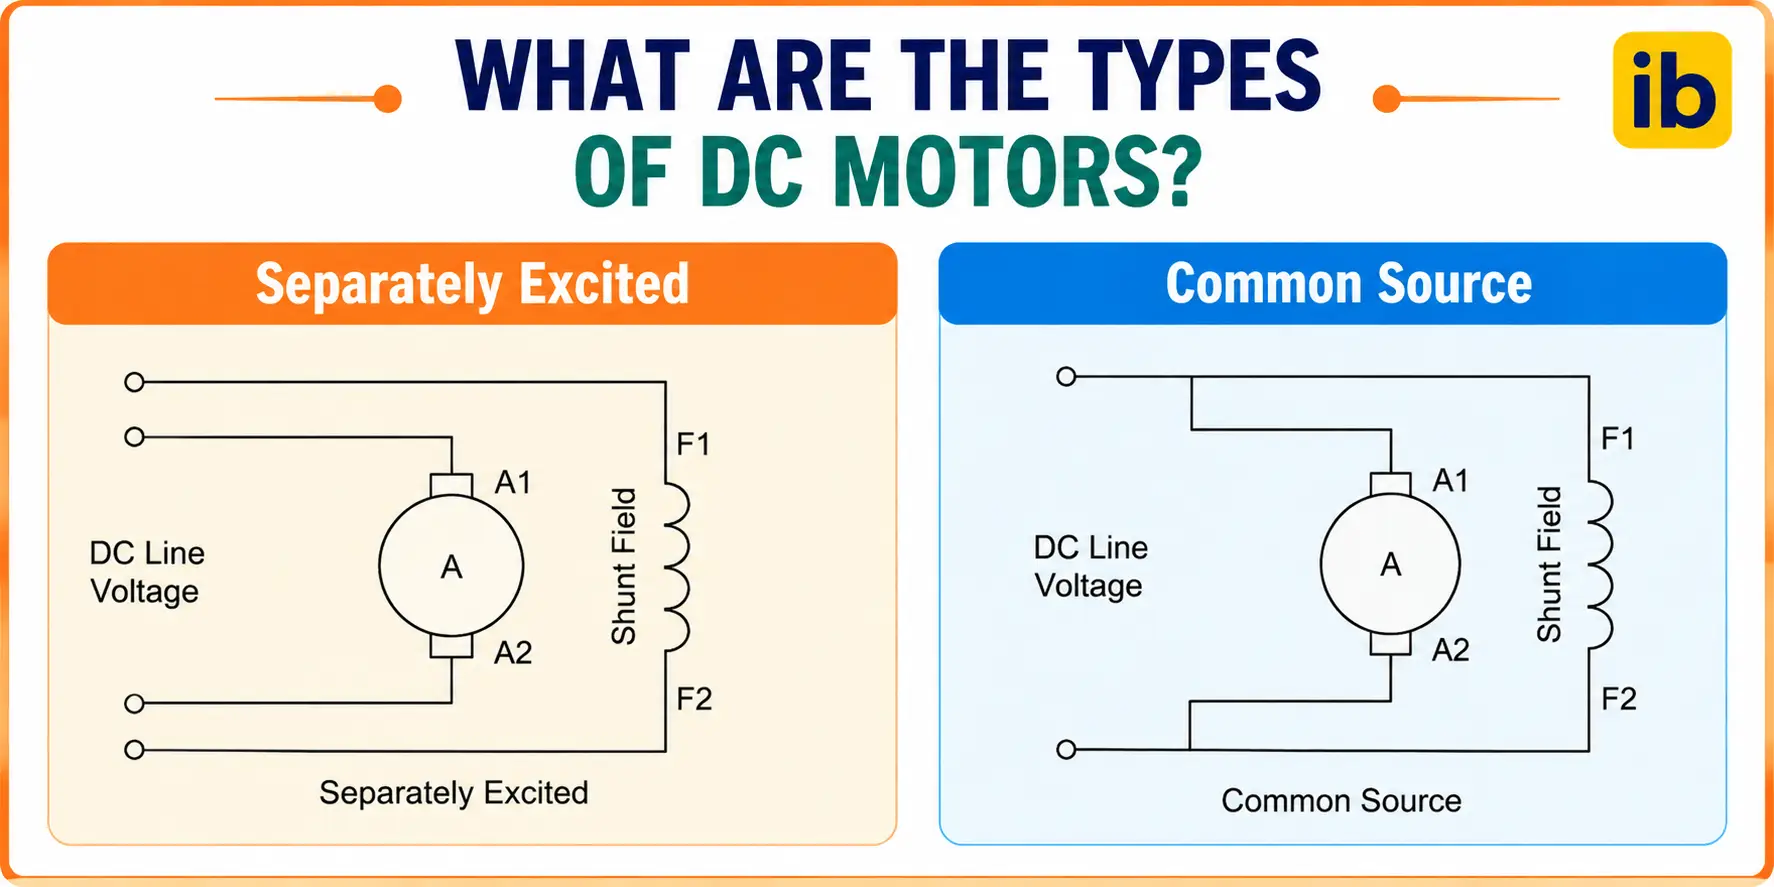
What Are DC Motor Types?
DC motor types are the different ways a DC machine produces its magnetic field, either with permanent magnets or with field windings connected in various ways. Each arrangement gives a distinct speed and torque curve, based on the back EMF principle shared by all motors.
Every DC motor has an armature that rotates inside a magnetic field, with a commutator and brushes reversing current in the coils. The difference lies only in how the field is created and supplied.
Although AC induction motors now dominate industry, DC machines remain common in cranes, traction, steel mill drives and battery powered equipment. They offer simple speed control and high starting torque.
Modern brushless DC motors replace the commutator with electronics, but the classic brushed types are still widely taught and used.
5 Proven DC Motor Designs
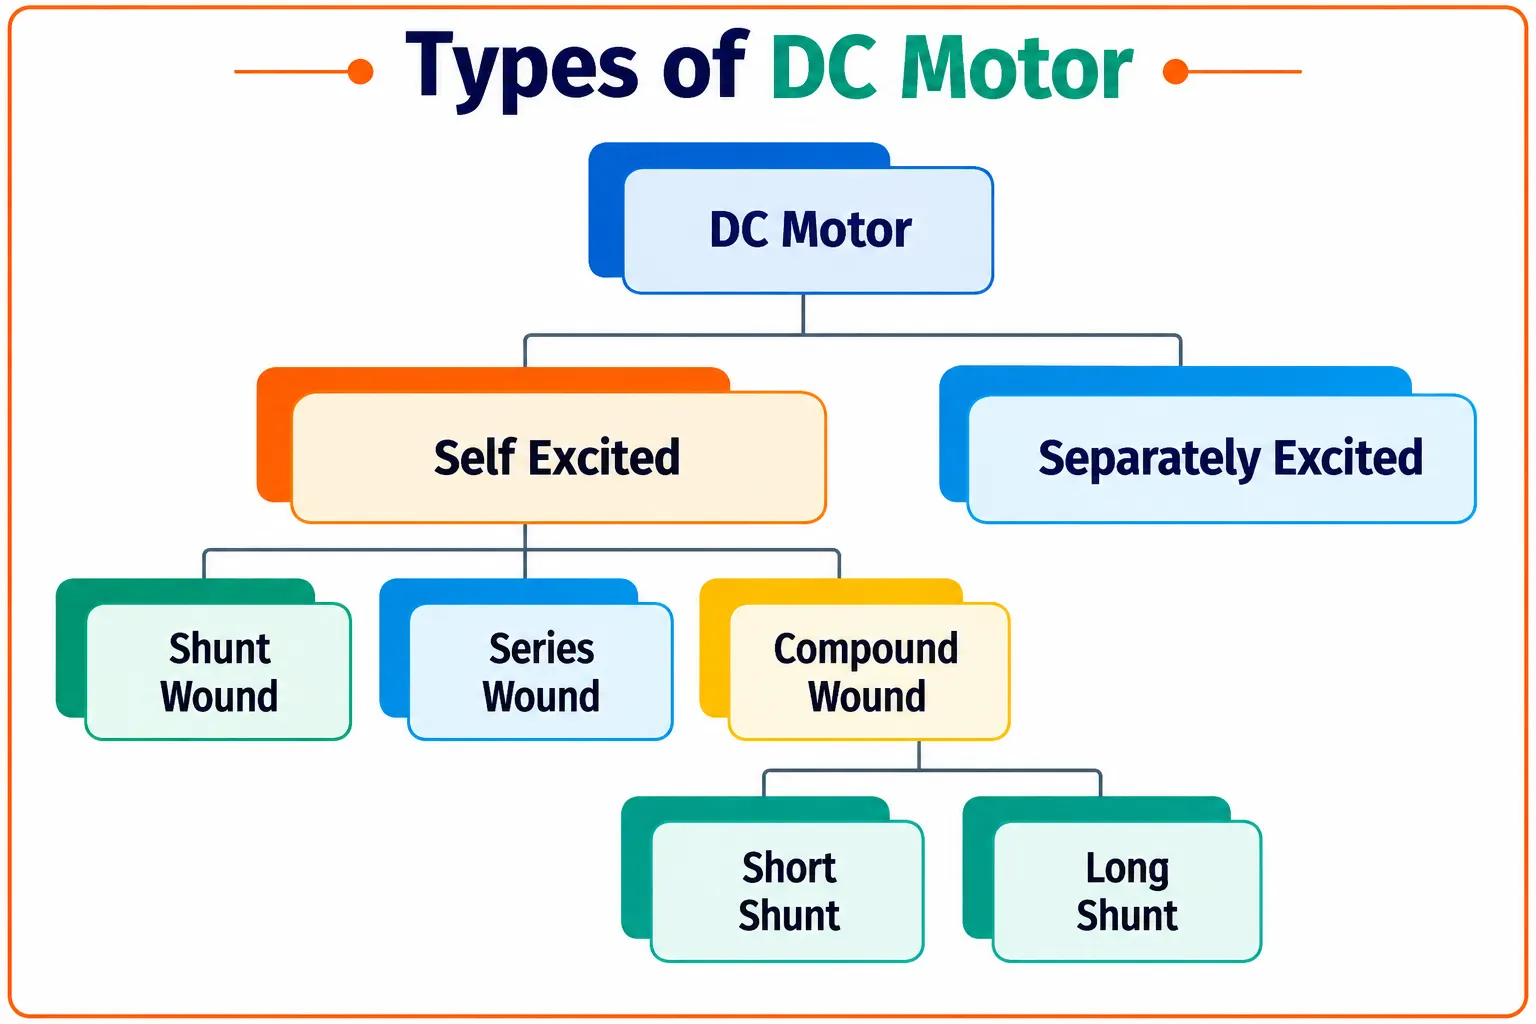
Shunt motors slow down only slightly as load increases, so they suit machine tools and fans. Series motors can race dangerously at no load, so they must always stay coupled to their load.
Compound motors come as cumulative, where the fields add, or differential, where they oppose. Cumulative compound is the common practical choice, and it may be connected long shunt or short shunt.
How Field Connection Shapes Performance
In a series motor, field current equals armature current, so flux rises with load. That gives torque roughly proportional to current squared at light loads, which explains its starting power.
In a shunt motor, flux stays almost constant, so speed depends mainly on the small armature voltage drop. That is why speed regulation is typically only a few percent.
Back EMF and Speed Formula
Speed N ∝ E ÷ Φ
Worked example, shunt motor with constant flux:
V = 220 V, Ra = 0.5 Ω
No load: Ia = 2 A, E1 = 220 minus 1 = 219 V at 1500 rpm
Full load: Ia = 20 A, E2 = 220 minus 10 = 210 V
N2 = 1500 × 210 ÷ 219
N2 ≈ 1438 rpm, regulation about 4.3 percent
Small speed drop with load is exactly what makes shunt motors useful where steady speed matters. A series motor would show a far larger change under the same load swing.
The same relationship explains why weakening the field raises speed. Our guide on DC drive mistakes warns about losing field current, which can cause dangerous overspeed.
Comparison of DC Motor Types
| Type | Speed Regulation | Starting Torque | Typical Use |
|---|---|---|---|
| Separately excited | Excellent with control | Adjustable | Rolling mills, test rigs |
| Shunt | Good, nearly constant | Moderate | Lathes, fans, pumps |
| Series | Poor, varies widely | Very high | Cranes, hoists, traction |
| Cumulative compound | Moderate | High | Presses, shears, elevators |
| Permanent magnet | Good | High for size | Automotive, small drives |
The table shows why DC motor types were chosen by duty in older plants. Traction and hoisting favoured series machines, while process lines used separately excited drives.
Today many of these duties use AC motors with a VFD, but DC machines remain in service across many Indian plants.
Where DC Motors Are Still Used
Small robots and automation often use PMDC or servo motors, compared in servo vs stepper motors.
Maintenance focuses on brushes and the commutator. Worn brushes and dirty commutators cause sparking, heat and radio interference.
Selection and Maintenance Tips
Match the motor to the load curve first, then check starting current and speed range. Never run a series motor without a mechanically coupled load.
Check insulation and thermal class during overhauls, as covered in motor insulation classes. Record brush length and commutator condition at every inspection.
Protect the field circuit on shunt and separately excited motors with field failure relays. Losing field while armature voltage remains can overspeed the motor quickly.
Speed Change Calculator
This simple model assumes constant flux, which suits shunt and separately excited motors. Series motors need their magnetization curve for accurate results.
- Simple and wide speed control.
- High starting torque in series types.
- Good low speed performance.
- Direct use of battery supplies.
- Brushes and commutator need maintenance.
- Sparking limits use in hazardous areas.
- Series motors can overspeed at no load.
- Higher cost than induction motors.
DC Motor Lecture Notes PDF
Series, Shunt and Compound Machines Video
DC Motor Types FAQ
Related Articles
- Brushless DC Motor Working Principle
- Back EMF in Motors and Generators
- How AC Induction Motor Works
- DC Drive Mistakes and Prevention
- Servo Motor vs Stepper Motor
External References
- Types of DC Motors, Electrical4U
- DC Motors Lecture Notes, Rose Hulman
- Series, Shunt and Compound Motors, CircuitBread
- DC Motor, Wikipedia
What We Learn Today
- Field connection decides speed regulation and starting torque.
- Shunt motors hold speed, series motors deliver high starting torque.
- Back EMF and flux set speed, so losing field can cause overspeed.